 SpanDraft
Forces, moments and distributed loads
Loads describe the prescribed actions in the two-dimensional bending plane.
Point force
A point force F acts at a position x, including at a beam end. Its sign determines its direction.
F > 0 · upwardF < 0 · downward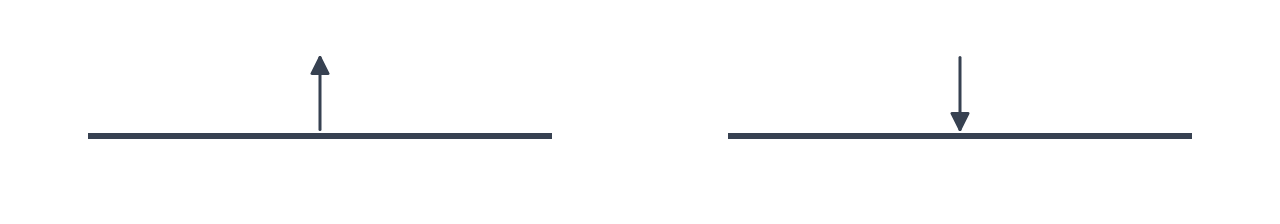
Point moment
A point moment C is an external moment applied at a position x. It causes no jump in the shear force there. In the toolbar, select Moment and enter the value of C in the Moment M field. The result diagram uses M(x) for the internal bending moment.
C > 0 · counterclockwiseC < 0 · clockwise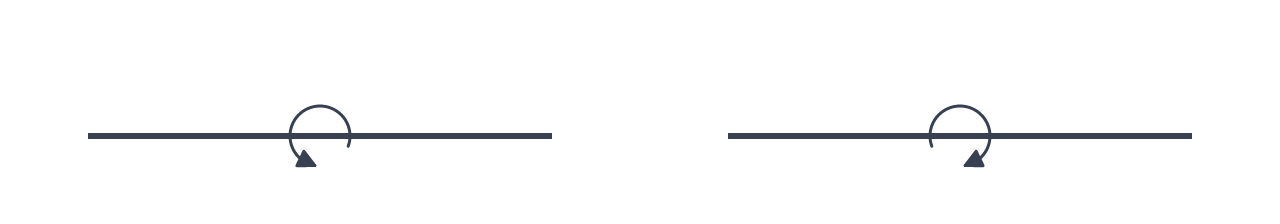
Multiple point forces and point moments may act at the same position.
Distributed load
A distributed load acts from xStart to xEnd and is a force per unit length. The start and end positions define the loaded region, with 0 ≤ xStart < xEnd ≤ L. It has two values: q₁ at the start and q₂ at the end. The intensity varies linearly in between.
- With
q₁ = q₂the load is constant. - If one value is zero, the load is triangular.
- If both values are nonzero and different, the load is trapezoidal.
- If
q₁andq₂have opposite signs, the load changes its direction within the region.
q > 0 · upwardq < 0 · downward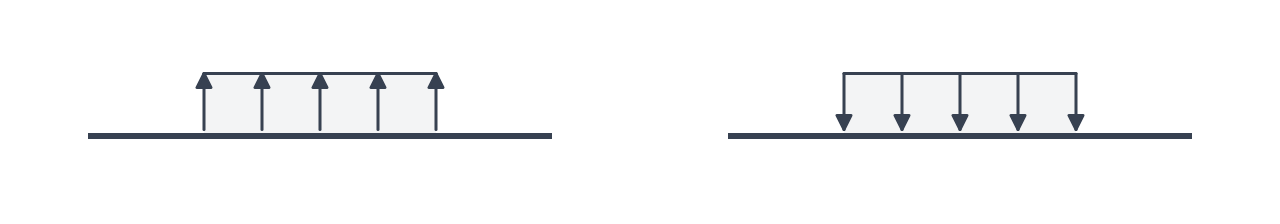
When you create a distributed load, q₂ follows the value of q₁ until you change q₂ yourself. A constant load therefore needs one value; for a triangular or trapezoidal load, also enter q₂. In the drawing, the arrow height is proportional to the magnitude of the intensity relative to the larger of the two end values, and the arrow direction follows the sign.
Multiple distributed loads may overlap. Their signed intensities are added.
Resultant of a distributed load
The resultant force is Fq = (q₁ + q₂) / 2 · (xEnd − xStart). For a constant load it acts at the center of the loaded region. With a sign change it can be zero although the load produces a moment, for example an antisymmetric triangular load; SpanDraft therefore does not show a line of action of the resultant. This equivalent force describes the global equilibrium. For deflection and internal-force calculations, SpanDraft continues to treat the load as distributed.
Self-weight
Self-weight is an optional distributed load derived from the current material and cross-section; with several segments it is one constant load per segment from that segment’s material and cross-section.
When enabled, SpanDraft calculates a downward constant load over the full beam length from the material density ρ, cross-sectional area A, and standard gravity:
q_g = −ρ · A · g₀, with g₀ = 9.80665 m/s².
A density must be defined for the material before self-weight can be enabled.
The self-weight load is shown as g. This name is reserved for self-weight; existing supports or loads named g or G must be renamed first. Its value follows the current material density and cross-sectional area. Hiding the self-weight load affects only its display; disabling it removes the load from the mechanical model.
Limits of the load model
Axial or inclined forces and torsional moments are currently not supported load types.
For the wider model limitations, see What SpanDraft calculates – and what it does not.
Next: Result diagrams and support reactions.
Technical background: Loads, supports and internal forces and moments.